K E Y R E S O U R C E S :
p r o t o t y p i n g (link)
• what are we designing?
• examples
• prototype help
• materials and where to buy
• arduino code & coding
• working with the shop (D2FS)
p o s t e r s & v i d e o s (link)
• guide: videos, posters, reports
c o u r s e p o l i c i e s (link)
• my course policies
• consent form for this course
• DEA/HCD statement
c o u r s e c u l t u r e (link)
• design culture
• class organization
• societies, jobs, opportunities
d e s i g n m e t h o d s
• ideation methods:
• Collage; example how to.
• Scenario; example
• Storyboard; ex. 1, 2
• Morphological Chart; example; morphological chart worksheet.
• WoZ
• GIF ex. 1, 2, 3, 4, 5, 6.
by Photoshop, Figma, Gif Maker.
• user study methods:
• Role Playing with a Think Aloud
• Observation
• Heuristic Evaluation
• Survey for UX and Usability (SUS)
• more methods:
• Design Guide
s t u d e n t e x a m p l e s
from all of my classes, to share excellent work. The content of these videos and reports may not align with the specific design challenge for your course. Consider carefully what you need to do specifically for your course in your semester!

ehoura for the ISS [video] [doc]
The Ice Breaker [video] [doc]
anima [video] [poster]
haptic desk [video] [doc]

voyager box
[video] [doc]

invisible stations [video] [doc]

infinity wonder box [video] [doc]
SoundSoul
[video]
Growbot [video] [pub]
ACM DIS BEST DEMO PAPER

e-MoBo [video] [pub]
IEEE RO-MAN BEST PAPER
SocialStools
[video]
SORT
[video]
pheB [video]
- - - - - - - - - - - - - - - - - - - - - - - - - -
i n s p i r a t i o n :
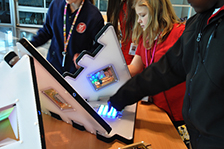 The first cyberPLAYce from my lab, reported in my foundational paper (more here).
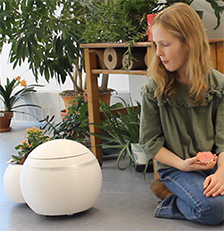
growbot, an outcome from a previous course of mine, aims to encourage children to notice and sustain indoor plant life (more at the bottom of this page).
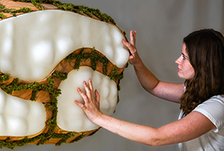
pheB, from my lab, also aims to encourage people to notice and sustain indoor plant life, but targets people of all ages living in tight confines (more here).
|
 |
Designing Robots for CyberPLAYces
D E S I G N S T U D I O
Keith Evan Green, Ph.D. > w h e e l o f n a m e s
TA: [tbd], xxx@cornell.edu to select work to review + critics
Tu. and Th., 2pm-4:30pm, HEB 2L32
C O U R S E D E S C R I P T I O N | D E A 5 2 1 0
As digital experiences can isolate us from physical places and embodied play, familiar environments offer opportunities to reconnect through human-centered robots. Using microcontrollers, sensors, motors, LEDs, and manual and digital fabrication techniques, students design, prototype, and evaluate small robots that foster play, community, and engagement towards establishing CyberPLAYces resonant with our emotional and social lives.
P R E R E Q U I S I T E S | E N R O L L M E N T
• Enrollment capped at 18 students to make full use of the D2FS shop.
• Requires professor's permission by email. DEA majors must have completed two DEA studio courses at the 2000 and 3000 level.
• Preference is given to student in my affiliations: DEA, FSAD, MAE, IS, and Robotics.
• 3 credits; letter grade only; no final exam.
• No prior coding or electronics experience is necessary to do well in this course.
S Y L L A B U S | S E E A L S O M Y D E A 6 2 1 0 a n d D E A 2 7 3 0
---------------------------------------------------------------------------------------------------------------
N O D E V I C E S P O L I C Y - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - -
The use of phones, tablets, and laptops is prohibited in class except for class activity focused on Arduino prototyping when laptop-use is required. Leave your mobile phones in your backpacks and be with us; you'll be more engaged and do better in this course. The evidence for this is clear. If you have an exceptional need for using these devices in class, talk to me about it.
L E A R N I N G O U T C O M E S - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - -
Outcome 1: To grapple with under-constrained, “wicked” problems and opportunities of living on this planet.
Outcome 2: To demonstrate an ability to design, prototype, and evaluate full-scale, small robots responsive to these problems and opportunities, and present them in a video.
Outcome 3: To demonstrate, in a written report, an ability to communicate the motivations for, and iterative development of small robots that shape playful places, as well as assess their shortcomings.
This studio course is designed to guide you in designing meaningful responses to particilar life challenges while encouraging exploration of who we are, how we engage with the world, and our place within it.
"In order to understand things, we have to build them."
– Ruzena Bajcsy, a founder of modern robotics.
F O U N D A T I O N - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - -
As the boundary between physical and digital worlds blurs, there is a need for new digital tools and physical environments to support everyday cyber–physical interaction.
This studio focuses on designing and building technologies—small robots—that do more than serve practical purposes: they foster play, community, and engagement while helping establish what I call "CyberPLAYces."
A CyberPLAYce combines digital tools and physical environments to create cyber-physical places resonant with our emotional and social lives.
My foundational paper, cited below, elaborates on the motivations and theories anchoring a design exemplar of a CyberPLAYce:
Soleimani, A., Herro, D., Green, K. E., and Walker, I. D. 2019. “CyberPLAYce – A Tangible, Interactive Learning Tool Fostering Children’s Computational Thinking through Storytelling." International Journal of Child-Computer Interaction, Elsevier, 20C, pp. 9-23. https://doi.org/10.1016/j.ijcci.2019.01.002
This studio aims to expand this design space, recognizing that, while our world is increasingly digital, it can also remain grounded in physical environments that enable embodied, social and emotional life.
R E A D I N G S - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - -
There are no assigned readings for this course, but the readings listed below lay an intellectual foundation for what we do in this studio.
• Paul Dourish. Embodied Interaction. MIT Press, 2001.
• Steve Dow. Wizard of Oz Interfaces [WOZ].
• Jen Golbeck. Back off, man. I’m a scientist.’Using Fiction to Teach Beginners HCI.
• Kristina Höök. Affective Interaction.
• Hiroshi Ishii. Tangible Bits and Radical Atoms: Beyond Tangible Bits.
• Bruce Mau. An Incomplete Manifesto for Growth.
• John McCarthy and Peter Wright. Technology as Experience. MIT Press, 2004.
• William J. Mitchell. Computers for Living In, from e-topia. MIT Press, 1999.
• Nicholas Negroponte. Soft Architecture Machines. MIT Press, 1970.
• Richard Picard. Affective Computing. MIT Press, 1997.
T H E P O W E R O F A S M A L L C L A S S - - - - - - - - - - - - - - - - - - - - - - - - -
Unlike a large lecture class at Cornell, this small class offers a unique opportunity for meaningful conversation, discovery, and collaboration. Don’t miss out on this chance to engage! To ensure attendance, a sign-in sheet will be available during the first ten minutes of each session. Additionally, a significant portion of your grade will be based on your active participation in collaborative learning and discovery (in part, by evidence of written peer evaluation).
C L A S S O R G A N I Z A T I O N - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - -
This is a studio course. As such, most of our classes together involve: (a) student updates on developing work, and (b) students working on assignments in class, supported by the resources available—the instructor, TA, shop staff, and fabrication facilities.
A typical class follows this sequence:
1. At the start of class, the professor will very briefly locate a given class session on the course page below, make annoucements and reminders, and will screen a short case-study video of an interactive physical artifact or robot. These examples will identify to identify possible interactions, materials, mechanisms, behaviors, and design strategies relevant to the day’s studio work.
2. As selected by the wheel of names, students or student teams will be called upon to present developing work (design materials and demos, as per the schedule below), and student critics will be called upon to offer their input. Design materials and video-demos must be uploaded to the shared class folder before class presentations unless instructed otherwise in class. For demos (except for the EXPOLARATORY ones), share your current physical prototype AND take a smartphone video of your working prototype and upload the video (or a URL to it) to our shared folder. Constructive, specific, and generous critique from student reviewers—as well as consistent attendance and preparation—will form a substantial basis of the participation grade.
3. Following the two activities above, the professor and TA will work with each student or team to advancedesign work. Students will also continue independent and collaborative studio work, seek peer feedback, use shop and fabrication resources as appropriate, and document progress for the next session's student presentations.
For broader expectations about working together, please review course culture: link.
S C H E D U L E B Y W E E K - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - -
SHOP TRAINING: We will complete D2FS shop training to use basic power tools safely. Wear closed-toe shoes; tie back long hair.
STUDENT CRITICS: At each studio meeting, one or more student critics-of-the-day will be selected randomly to offer constructive feedback on peers’ developing work. This is a central studio practice: we learn from one another.
METHODS: See top-left of this page for more on human-centered design methods, including scenarios, storyboards, morphological charts, role playing with think-aloud, observation, heuristic evaluation, GIFs, and Wizard-of-Oz prototyping. These methods will be used as needed but will not be formally taught in this studio as I do in my DEA 2730.
BRING A LAPTOP AND GROVE KIT TO CLASS, ALWAYS!
Week 1 | Introduction to Course; Get Grove to Work | clap, heart by Martin Smith
> Tu 01.26 Syllabus; Red Desert; Grove slides, video; link; Make something Industrial.
> Th 01.28 D2FS shop training; An Incomplete Manifesto; Make movement expressive.
Week 2 | Hardware Possibilities | Zimoun—works; Sounds like a hug
> Tu 02.02 ESP-NOW: short message across XIAOs: call-response, distributed, ripple.
> Th 02.04 XIAO Web Interface: phone/laptop controls light, sound, movement, modes.
Week 3 | Morphological Charts to 3 Exploratory Prototypes | Lovebox; Flow
> Tu 02.09 No class. Winter Break.
> Th 02.11 Do a morphological chart > 3 Grove prototypes in corrug. plastic, 8"x8"x4".
Week 4 | Exploratory 8"×8"×4" Corrugated Plastic Prototypes | Good Night Lamp
> Tu 02.16 DEMO DAY: upload one slide with 3 phone-video demos [5 pts]—rubric.
> Th 02.18 Poster Concept: title, atmosphere, interaction, I/O, servo mech., sketch.
Week 5 | Full-Scale 16"×16"×6" Plywood Prototype Development: I/O | e-MoBo
> Tu 02.23 Develop the full-scale prototype: Input & Outputs (movement LED, sound).
> Th 02.25 Advance the full-scale prototype.
Week 6 | Full-Scale Prototype Development, Storyboard, Role-Play | SocialStools
> Tu 03.02 DEMO input & outputs (movement LED, sound); Wall-scale design.
> Th 03.04 Wall-scale design with ESP-NOW; storyboard it (ex. 1, 2); role play it.
Week 7 | Storyboards, Full-Scale Prototype Demo, Wall Assembly | little printer
> Tu 03.09 DEMO DAY: Refined Prototype [10 pts]—rubric
> Th 03.11 Wall assembly and collective behavior test.
Week 8 | Wall Collective Behavior Testing; Introducing Assignment-2 | haptic desk
> Tu 03.16 Wall behavior test-2; EXPO strategy; Video + Report [25 pts]—rubric
> Th 03.18 Intro Assignment-2; form teams; meet and GIF; complete a team charter.
Week 9 | Assignment-2 Concepts | sapling
> Tu 03.23 Storyboard it; Morphological chart it; Order components/materials needed.
> Th 03.25 Each team member prototypes one outcome of team's morph. chart.
Week 10 | Cornell Break
> Tu 03.30 No class.
> Th 04.01 No class.
Week 11 | Assignment-2 Exploratory Prototypes | yoto
> Tu 04.06 DEMO DAY: upload one slide with phone-video demos [5 pts]—rubric
> Th 04.08 Team converges on one design and presents a demo.
Week 12 | Assignment-2 Concept Validation Prototype | MusicalBottles
> Tu 04.13 Design development.
> Th 04.15 DEMO DAY: Assignment-2 Concept Validation Prototype [10 pts]—rubric
Week 13 | CU HCD Design Expo Week | class members at our booth! | Cubelets
> Tu 04.20 Advance Assignment-2 prototypes.
> Th 04.22 Debrief on Expo experience; Advance Assignment-2 prototypes.
Week 14 | Refinement and Think-aloud | MirrorBot
> Tu 04.27 Each team demos, while members of another team think aloud.
> Th 04.29 Final Build.
Week 15 | Refined Prototypes, Assignment-2
> Tu 05.04 DEMO DAY: Refined Prototype [10 pts]—rubric; complete peer evaluation.
> Th 05.06 Final Deliverables (Video and Report) Workshop.
Week 15 | Final Class
> Tu 05.11 Final Deliverables (Video and Report) Workshop.
DEADLINE for Assignment-2 Videos and Reports: TBD [25 pts]—rubric
Upload all final deliverables to our shared folder for grading by date/time announced each semester by Cornell U. Registrar as offered here.
A S S I G N M E N T S - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - -
There are two assignments for this course.
The first assignment, undertaken by each student, is intended to be a fast-paced engagement.
The second assignment is undertaken by teams of 2-4 students and provides a longer, deeper development of the design following a trajectory like this:
- Conceptualization
- Prototyping / Rapid, low-fidelity
- Concept Generation: GIF, Scenario, Morphological Chart, Storyboard
- Prototyping in Hardware and Software
- User Testing
- Video Making and Reporting
- Documentation
Team composition for the second assignment will be formed by the instructor(s) based partly on proposals pitched in class by class members.
Keep in mind: this course asks you to develop interactive, physical artifacts that have at least one input and one output which moves physical mass.
- - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - -
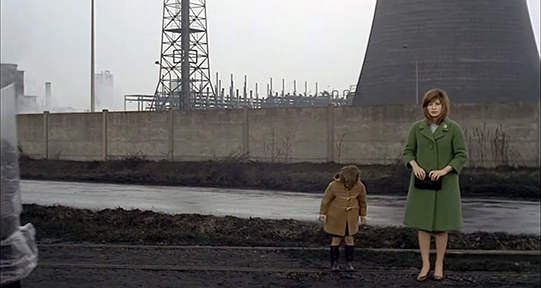 A stillframe from Michelangelo Antonioni's Red Desert (Il deserto rosso, 1964),
Introduction to this semester's assignment:
Industrial Landscapes, Living Systems: Robotics to Help Children Learn About and Care for the Environment
Over the past century, industrialization has both benefited and harmed society. It has expanded material comfort, transportation, communication, medicine, and the ability to produce housing, food, energy, and everyday goods for large populations. Yet it has also polluted air, water, and soil; warmed the planet, and changed weather patterns; depleted natural resources; exposed workers and nearby communities to unsafe conditions; and, in some places, contributed to physical illness, stress, anxiety, and social isolation.
Red Desert (Il deserto rosso, 1964), directed by Michelangelo Antonioni, asks us to attend to the harmful effects of industrialization: not only what an industrial landscape releases into the environment, but especially what it can do to the emotional lives of people who must inhabit it. Antonioni's film follows Giuliana, a young mother, and her son Valerio as they attempt to navigate the alienating industrial landscape of postwar Italy.
At the end of the film, mother and child stand beside the petrochemical plant in the town where the live. Valerio grasps a valve wheel emerging from the ground, near a pipe that releases steam violently at irregular intervals, and asks why it does that.
Giuliana: I don’t know.
Valerio: Why is that smoke yellow?
Giuliana: Because it’s poisonous.
Valerio: But if a little bird flies over there, does it die?
Giuliana: The little bird knows, by now, not to go over there anymore.
Giuliana’s answer is unsettling. It suggests that both birds and people are left to adapt to poisonous industrial emissions, while the industrial landscape that produces them goes on unchanged.
In the United States and around the world, chemical-plant emergencies, gas leaks, and industrial explosions regularly appear in the news. In 2026 alone, incidents covered include:
- “Toledo Chemical Leak That Forced Residents to Evacuate”
Toledo, Ohio (NYT: October 21, 20260
- “Toxic Explosion Feared at California Chemical Plant”
Garden Grove, California (NYT: May 22 and 25, 2026)
- “2 Are Dead After ‘Chemical Emergency’ at a West Virginia Plant”
Nitro, West Virginia (NYT: April 22, 2026)
- “11 Dead as All Bodies Recovered After Washington Chemical Explosion”
Washington State (NYT: May 30, 2026)
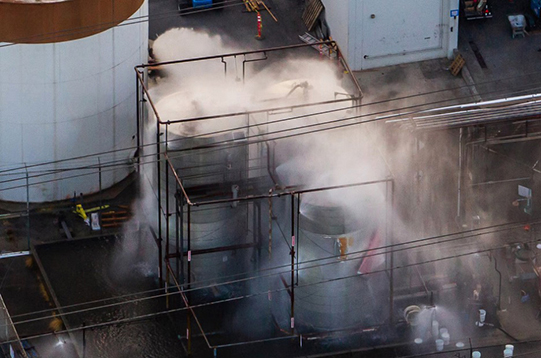
Chemical Explosion in Garden Grove, CA (NYT, 2026).
Today, widespread data-center construction is creating another form of industrial expansion. Data centers can produce adverse noise, light, air, water, and energy impacts for nearby communities. Their rapid growth has prompted concerns about hearing loss, stress, sleep disruption, diminished quality of life, and environmental burdens placed on surrounding neighborhoods. Studies cited by The New York Times estimate that pollution associated with data centers in the US may contribute to roughly 1,300 premature deaths and hundreds of thousands of asthma cases each year (October 1, 2026). As one might expect, public opposition to new data-center development has been forceful, as reported here:
- “Why Americans Hate Data Centers”— NYT: Sept. 15, 2026
- “The Data Center Backlash Bursts Into the Midterms”— NYT: Aug. 23, 2026
- “What the Data Center Boom Looks Like From the Sky”— NYT: Oct. 5, 2026
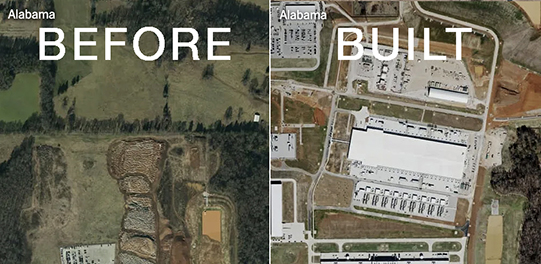
A site before and after a data center was constructed (NYT, 2026).
In this design studio, the two project assignments are motivated by the harmful effects of industrialization—effects now intensified by the rapid expansion of data centers.
The two assignments are cousins: the first asks you to make industrial harm perceptible by way of a robotic installation; the second asks you to design robotics in support of nature, care, and environmental stewardship.
Assignment-1 (40% of the course grade; individual effort)
A Robotic Wall that Helps Children Learn About the Harms of Industrialization
Each student will design and build one robotic unit: a wooden box measuring 16 in. × 16 in. × 6 in. Each unit will become one building block in a collectively assembled, reconfigurable wall. As a class, we will arrange these building blocks into wall-formations for exhibition.
Your unit should evoke an industrial environment and its effects on bodies, minds, and ecosystems. Your unit may include openings through which viewers can see into its interior, or through which light, sound, air, or moving elements can emerge. The robotic units should offer abstract evocations of the noises, sounds, and visible air pollutants using motors, LEDs, and audio outputs—not suggest, literally, the pipes, vents, smokestacks, conveyors, and other forms of infrastructure of an industrial facility.
The wall of units should be designed for elementary- and middle-school students as a learning too. Children will be able to approach, activate, and retune the robotic units to express their own understandings of pollution, industrial infrastructure, and environmental harm.
Each robotic unit must include:
- sensing of a visitor’s presence, movement, sound, touch, or other input;
- light/color output;
- sound output; and
- physical movement driven by the servo.
The movement component must do meaningful architectural or expressive work. It should visibly change the robotic unit’s physical state—for example, by opening a shutter, moving a vent, shifting a surface, releasing or concealing light, activating a mechanical sound, or changing the unit’s form. The goal is not simply to add a moving decoration, but to make the unit a small robotic component of a larger responsive environment.
Limit yourself to using only the Grove electronics and box panels provided. Ensure that the battery and all electronics fit inside the box, and that the battery is accessible for recharging. If you want to replace any wood panel with another material or otherwise modify them with engraving or cut-outs, generate your cut-files using a suitable program (e.g., Adobe Illustrator, AutoCad, SketchUp, CaseMaker) and work with the D2FS to have these cut. Don't make the mistake of creating a prototype that is not meticulously designed and fabricated; prototypes that look like craft projects will receive low grades.
You do not have to generate code on your own: you can select one of the codes provided under my “Arduino Codes You Can Copy & Paste” (link), An effective way to tailor your code to your wants without coding experience is to use ChatGPT as described in the linked page.
Finally, in addition to my foundational paper on CyberPLAYce referenced above, this paper may offer inspire your thinking:
Schneider, J. L., and Iverson, J. M. 2015. “Building Spaces for Play: Mothers’ Design of the Home Environment for Pre-Walking and Walking Infants.” Infant Behavior and Development, 39, pp. 79–89. https://doi.org/10.1016/j.infbeh.2015.02.004
- - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - - -
Assignment 2 (45% of the course grade; individual effort)
Growing Together: Child–Robot Partnerships for Plant Care
The second assignment moves in the opposite direction. Rather than conveying industrial harm, you will design a small robot that brings an evocation of nature into a school building that supports the care of living plants within it.
Working in groups of two to four, you will build a robot that shares responsibility for plant care with child-partners in an elementary or middle school. The robot may monitor plant conditions, invite watering or observation, communicate changes in a plant’s needs, create routines of care, or otherwise encourage children to notice and sustain indoor plant life.
The robot may take many forms and exhibit many kinds of behavior. It may use sensing, movement, light, sound, and/or AI vision. However, its central purpose must be clear: it should invite children into a relationship of care with plants and with the more-than-human world.
The aim is not for the robot to replace children’s care of plants. Rather, the robot should be a collaborator: one that helps plants thrive while cultivating attention, responsibility, curiosity, and environmental stewardship in children.
G R A D I N G / G R A D I N G R U B R I C - - - - - - -- - - - - - - - - - - - - - - - - - - - - -
Please review carefully the Course Policies (link). These policies are not negotiable except under grave circumstances.
Throughout this course—an intimate and intensive “conversation” across students and the professor— students will have ample opportunity to receive feedback on their work. Here is rubric for the two major assignments.
The list that follows names and describes the graded components for this course. Each component is worth so many points, as shown in red type. The sum of all of these components equals the final grade of 100 points. The numerical scale for grading is as follows: A+ (98–100), A (93–97), A- (90–92), B+ (88–89), B (83–87), B- (80–82), C+ (78–79), C (73–77), C- (70–72), D+ (68–69), D (65–67), D- (below 65).
• ATTENDANCE + PARTICIPATION | 15 points
DEA 5210 is intentionally designed as a low-enrollment course to foster a dynamic classroom experience centered on discovering together. As a result, each student’s active contribution to this shared exploration is a significant component of the final grade. For a broad description of what constitutes active participation, Review "P1" of the course policies (link). Practically, at the discretion of the instructor and teaching assistant (if any), up to 15 points will be awarded for these criteria:
- ATTENDANCE taken by the instructor or TA.
- CONTRIBUTIONS TO CLASS, especially when your work is selected for review in-class, when you are asked to be one of the two "critics-of-the-day" that critique the work of your peers, or you are assigned to present a case study in class.
- YOUR PEER REVIEW offered anonymously by team members using this peer evaluation form.
Active participation requires being present, prepared, and engaged when called upon. Your participation grade will be negatively impacted by repeated unexcused absences, unresponsiveness in class, and persistent distraction from phones, devices, or off-topic conversations.
• ASSIGNMENTS [rubric] | 40 points (A-1) and 45 points (A-2)
- EXPLORATORY PROTOTYPE [5 points]
A rough prototype demonstrating early technical feasibility and exploration of design directions. Focus is on getting things moving, sensing, communicating, or affecting space—however imperfectly—rather than polish or completeness.
- CONCEPT VALIDATION PROTOTYPE [5 points] for assignment-2 only
A more refined prototype that clearly demonstrates the core interaction concept. It shows that the main design idea is viable, with key functions working well enough to evaluate and iterate further.
- REFINED PROTOTYPE [10 points]
A near-final prototype demonstrating technical completeness and design maturity. Focus is on reliability, usability, and responsiveness to earlier feedback, and (for Assignment 2) exhibition-quality fabrication. Should be testable with real users or stakeholders.
- VIDEO [my guide] [15 points] communicates a full, cohesive story of your designed, interactive artifact, answering why, for whom, where, and for what purpose. Upload to our shared folder an MP4 file reduced to < 30MB using, e.g., Handbrake (see my video guide). In your Documentation, include a URL link to your video uploaded to Vimeo or YouTube. The video will otherwise adhere to the requirements for a Video Showcase submission to the ACM conference, CHI, a benchmark for design research. (Videos from a previous Video Showcase.)
- REPORT (print-quality pdf) [10 points] that includes every aspect listed in my grading rubric Including connections to E M Forster's short story and our assigned readings and theoretical frameworks. Upload your REPORT to our shared drive as a print quality pdf document. These examples from previous classes are model reports (1, 2, 3, 4) but they may not contain every requirement in my linked grading rubric. My grading rubric offers the most current expectation for documenting your design.
|
 |